The challenge
What needed solving
The robot needs component position information before picking. The imaging task is to locate the part and provide coordinates that the robot can use.
The solution
How Qualitas solved it
Vision processing locates the component in the image to support the robot-guidance task.
How the system works
The camera captures the component area and image processing locates the part. Calibration maps image positions to physical coordinates for the robot-guidance workflow.
Results and practical value
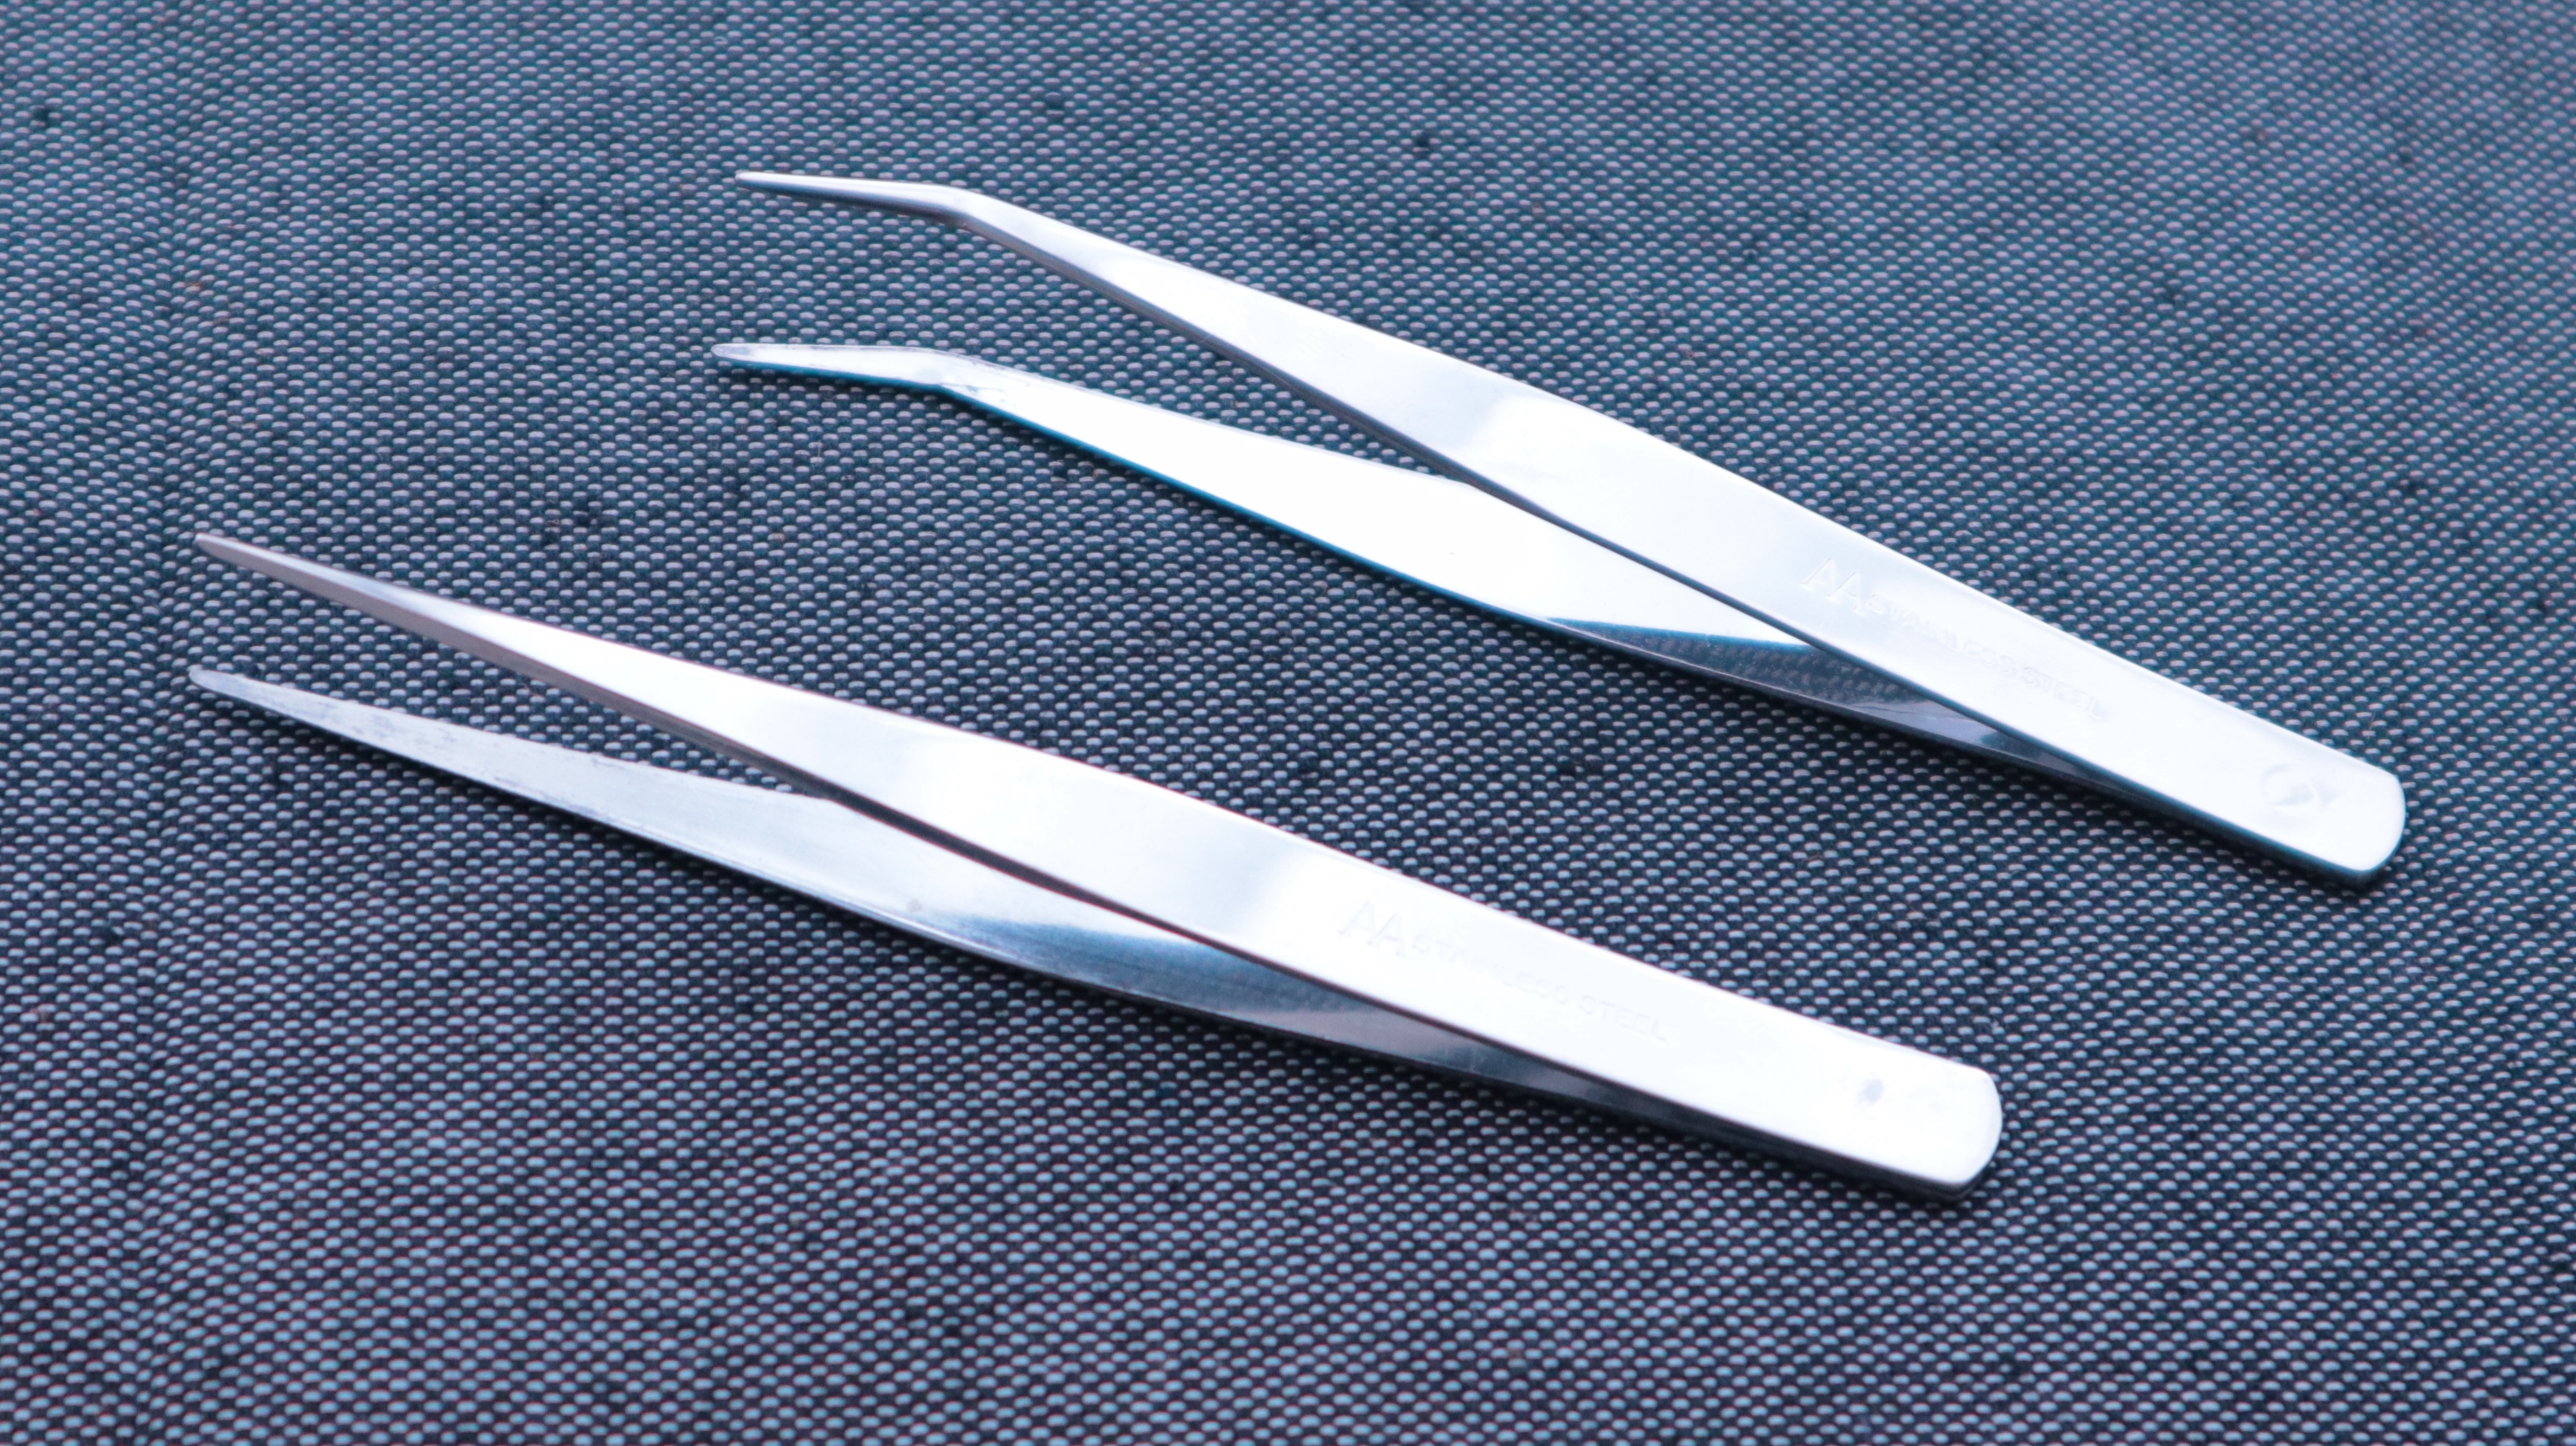
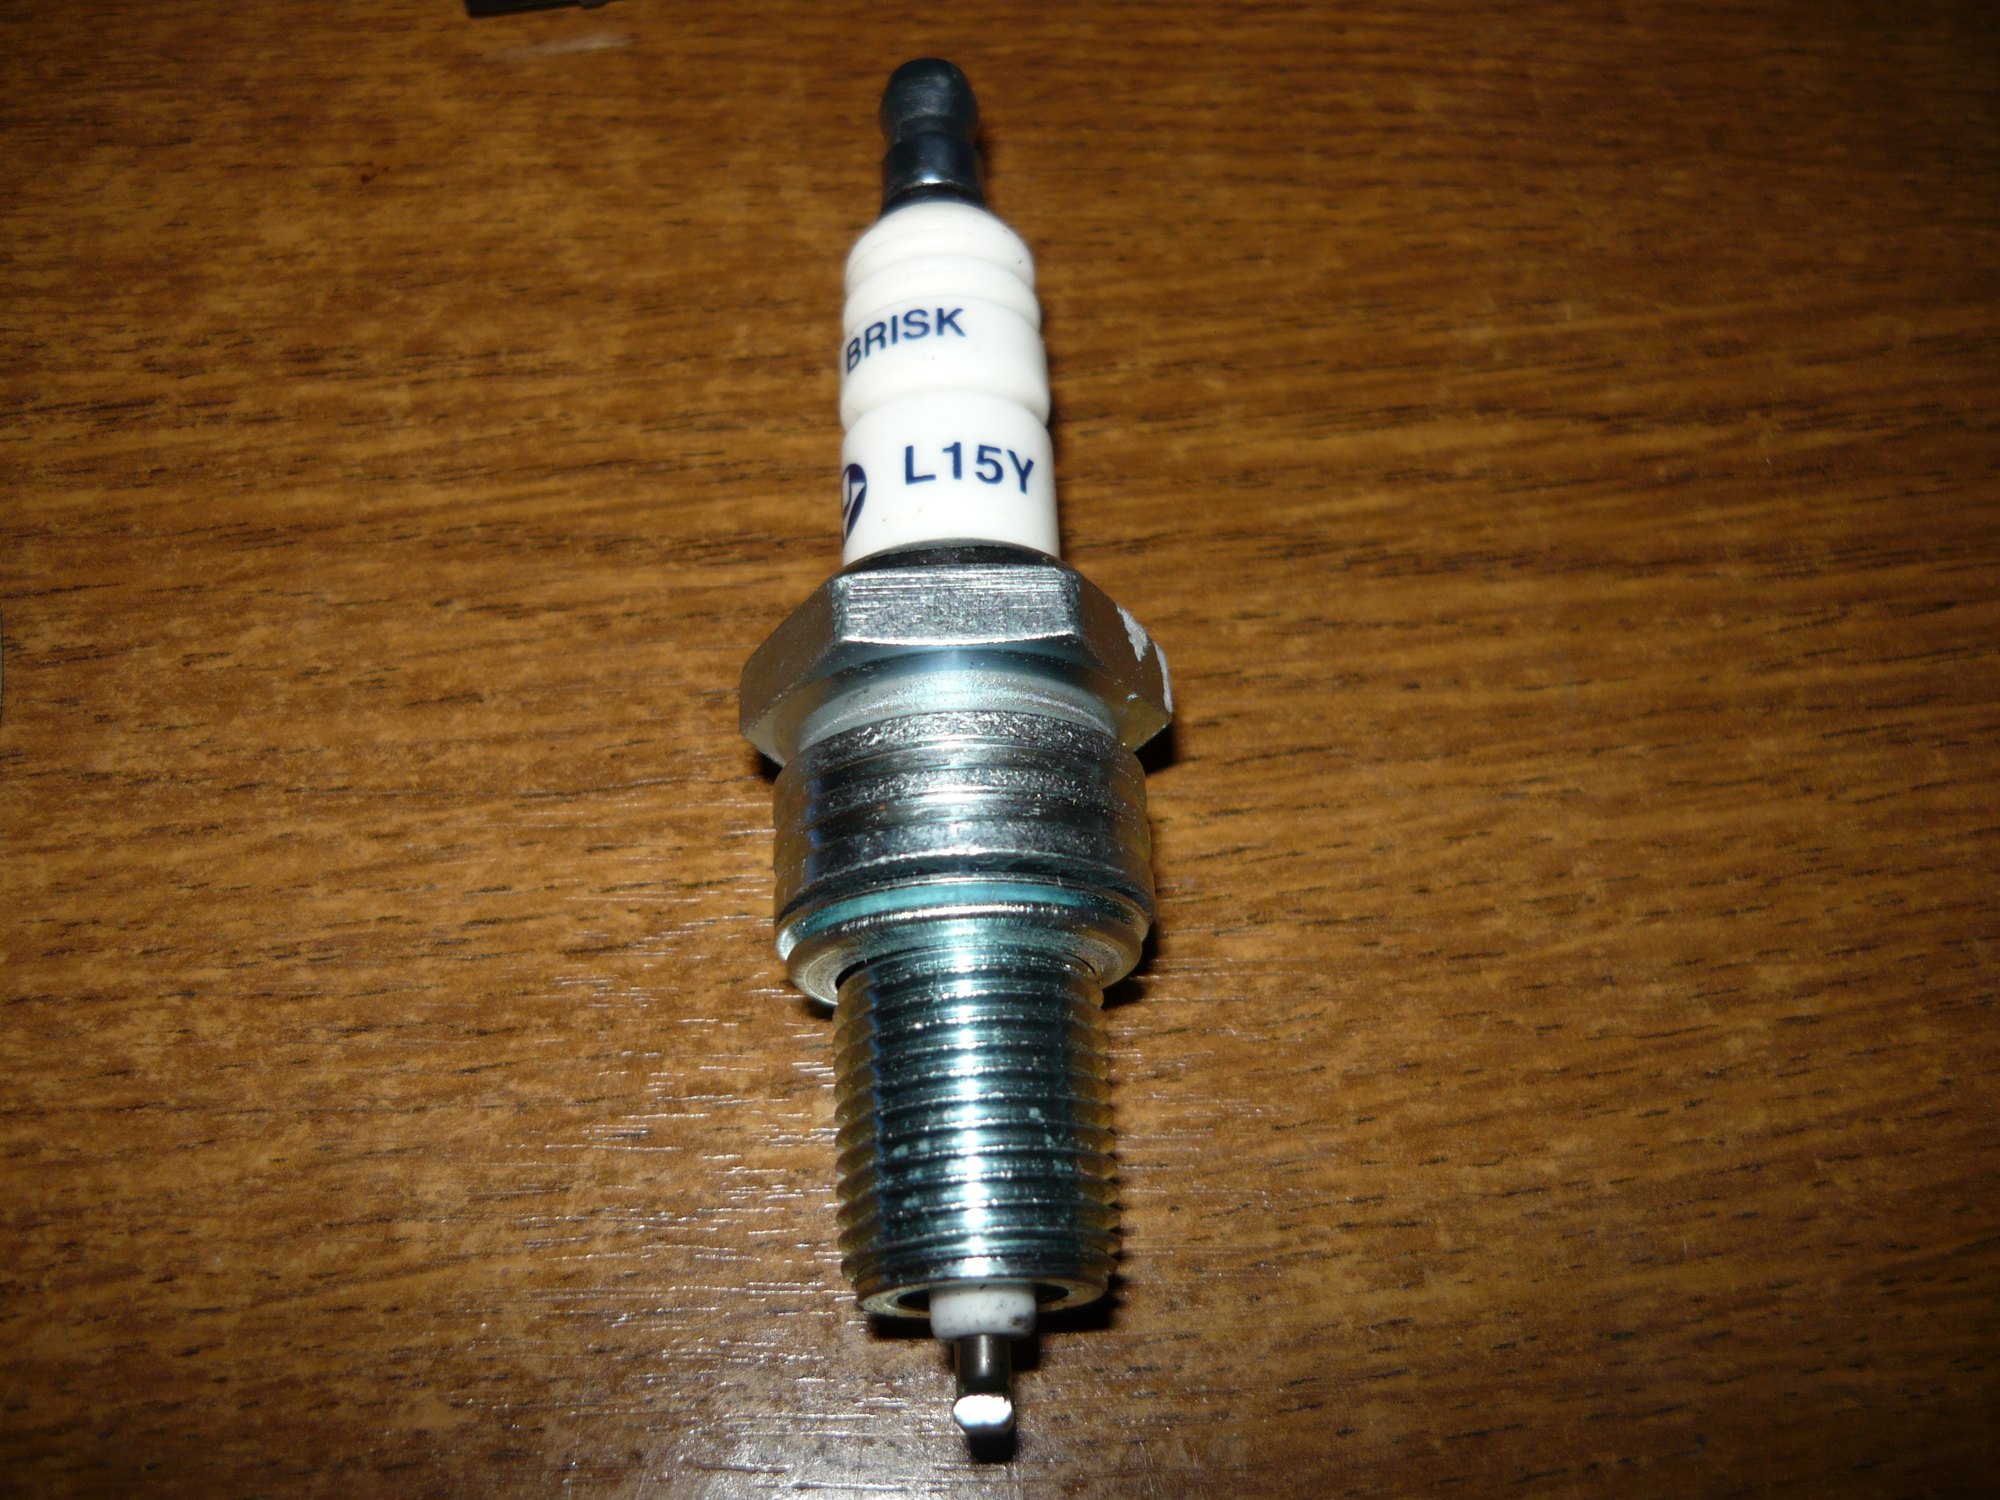
Component location turns a camera image into information that a robot can use for handling. The preview image shows the component-detection task.
Share component shape, presentation method, robot model and placement tolerance. We can assess camera coverage and the guidance interface.
Request project details